
P
Printablesandypacher
360° IR mapping Line Following Robot
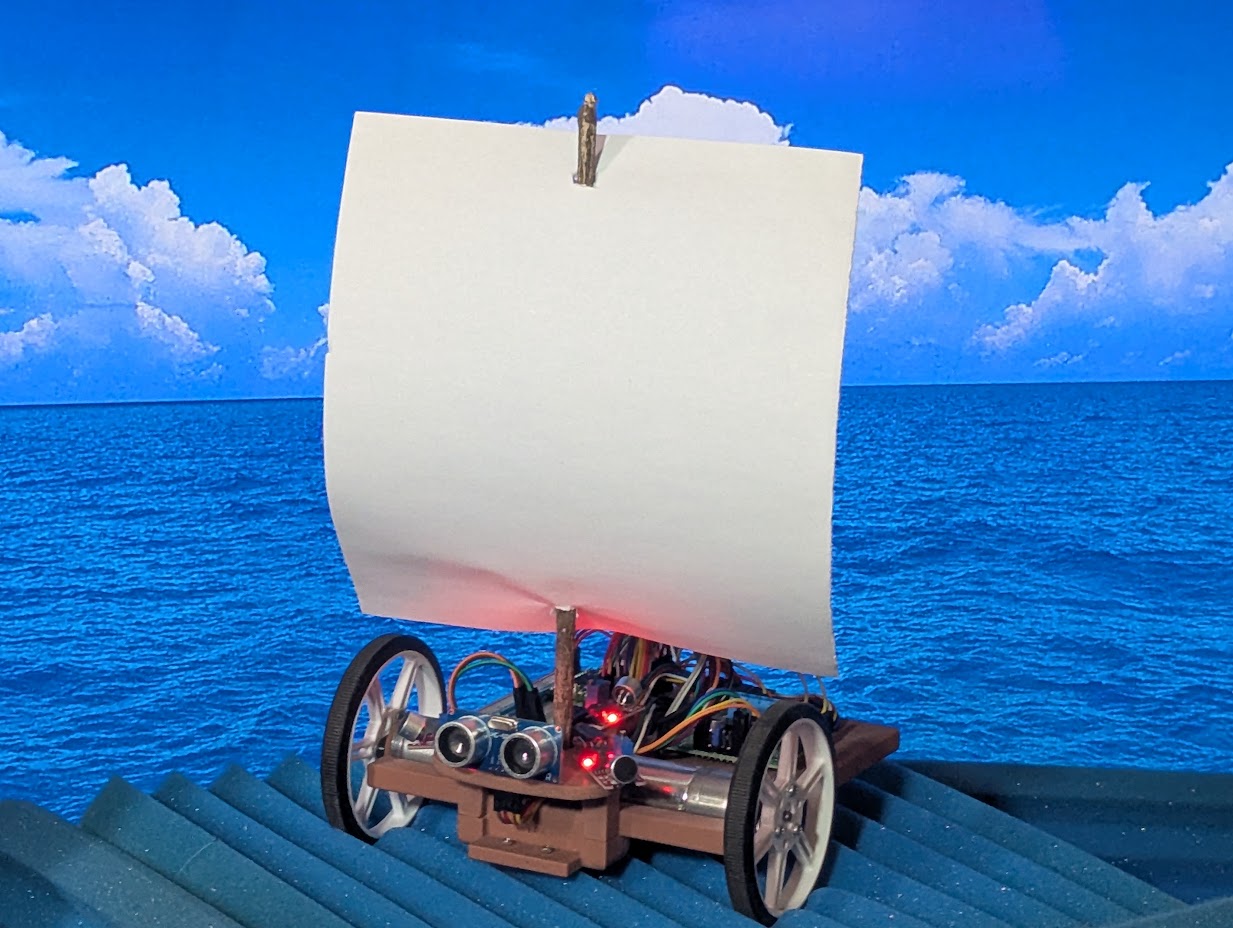
This line following robot was my final project for EEEE 485 and was required to demonstrate line following, obstacle avoidance, speed control, and a “personality trait.” My line following and speed control used DC motors and a QTR…
- Downloads
- 9
- Likes
- 2
- Rating
- 0