
3DPDiffWrist: 3D printed differential robot wrist
Obliczymy ostateczną cenę na podstawie wybranego pliku. Sprawdzisz ją i zaakceptujesz przed płatnością.
Zapisane na tym urządzeniu.
To build a simple differential wrist using almost 3D printed parts, and that could be used as base for other robots.
- Ocena
- 0 / 5
- Polubienia
- 0
- Pobrania
- 40
- Wydruki
- 1
- Wyświetlenia
- 193
- Oceny
- 0
Aktualizacja u źródła:
Informacje o modelu
- Źródło
- Printables
- Kategoria
- Mechanical Parts
- Licencja
- Creative Commons — Attribution — Share Alike
The idea is to build a simple differential wrist using almost 3D printed parts, and that could be used as base for other mechanisms. A robot arm, maybe. ;)
Run it for sufficient long time, plastic gears needs some breaking in. Have fun, most of all!
This is version zero, take it with a pinch of salt! Comments and suggestions are always welcomed!
For academic purposes quote this project using the Zenodo's reference DOI: Charters, Tiago (2026). 3DPDiffWrist: 3D printed differential wrist. Zenodo. https://doi.org/10.5281/zenodo.23287814
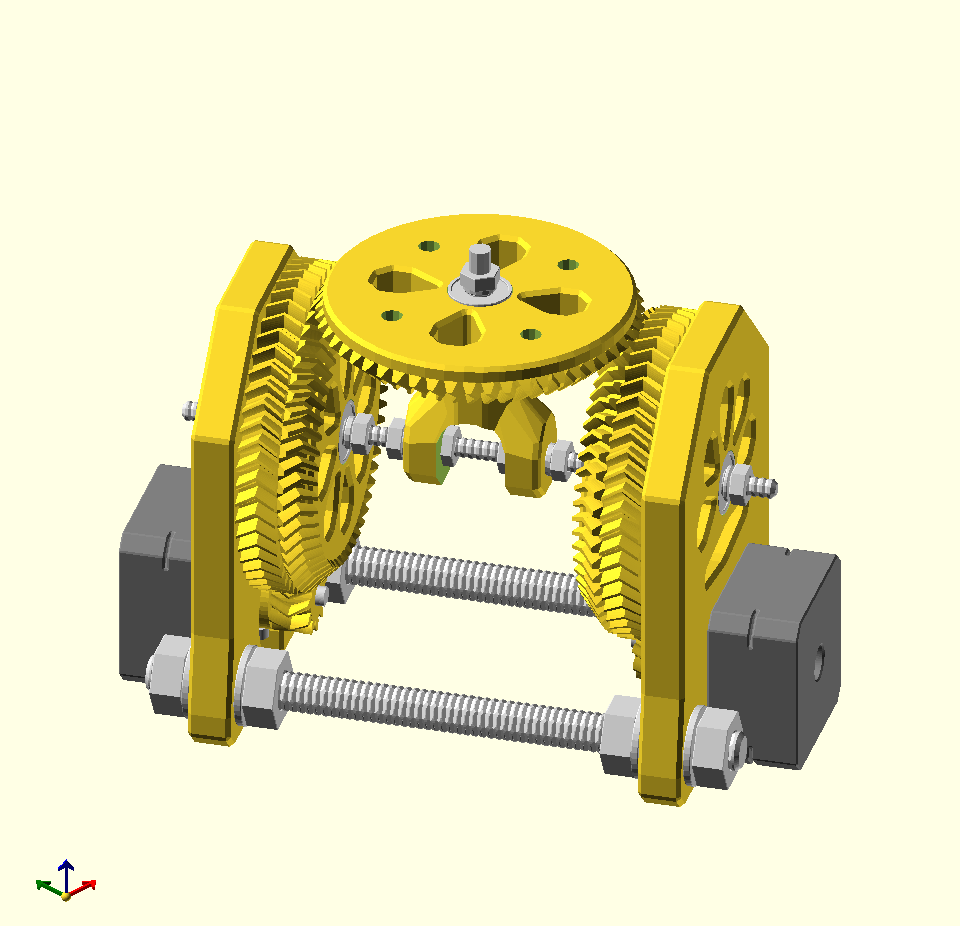
I'll try and make the building instructions concise and complete, any error or lack of clarity please contact me.
Printed parts
biggear.stl (x2 )
smallgear.stl (x2)
topgear.stl (x1)
plate.stl (x2)
center.stl (x1)
washer.stl (x2)
20%, 0.2mm layer height, no supports.
STL parts are oriented the right way i.e. oriented to be printed.
Vitamins
Qty | size | Description |
|---|---|---|
10 | 5x5x16mm | bearings |
10 | 10mm M3 | screws |
2 | M3 | nuts |
8 | M3 | washer |
2 | 200m M5 | threaded rod |
1 | 40mm M5 | hex screw |
16 | M5 | nuts |
32 | M5 | washer |
2 | 200m M10 | threaded rod |
8 | M10 | nuts |
8 | M10 | washer |
Some math
Depending on the NEMA motors that you have you may have to recalculate the stepsPer/Degree value. My motors are 1.8° steppers which have 360/1.8=200 steps/rev e.g. for 0.9° steppers one has 400 steps/rev.
NEMA 17 steps per revolution = 200
microsteps = 16
bigear teeth = 53
topgear teeth = 53
small gear teeth = 11number of steps per revolution (360 degrees) = 2001653/11
stepsPer/Degree = 2001653/(11*360) = 42.82828282828282...
This will go to GRBL defining steps/mm. See GRBL setup variables $100 and $101 below.
How does it work?
When motors rotate in opposite directions at the same speed: the input gears turn against each other, driving the differential top gear to pivot around its central cross-pin. This causes the wrist assembly to pitch up or down.
When motors rotate in the same direction at the same speed: both input gears rotate in unison, carrying the top gear around with them without turning the internal differential pin. This causes the wrist assembly to roll rotate on its axis.
When motors rotate at different speeds: the movement becomes a combined simultaneous pitch and roll.
So X is the value of the pitch angle and Y refers to the roll angle.
GCODE example
G0 X10 ;pure pitch
G0 Y10 ;pure roll
G0 X-10 Y3 ;pitch and roll combined
GRBL firmware
I'm using GRBL a cheap UNO + CNC shield with A4988 drivers, but any other combo would work. The differential wrist uses a COREXY control so if we're using GRBL enable COREXY (look for config.h in the GRBL src files).
GRBL 1.1h parameters
Grbl 1.1h ['$' for help]
$0 = 10    (Step pulse time, microseconds)
$1 = 255    (Step idle delay, milliseconds)
$2 = 0    (Step pulse invert, mask)
$3 = 1    (Step direction invert, mask)
$4 = 0    (Invert step enable pin, boolean)
$5 = 0    (Invert limit pins, boolean)
$6 = 0    (Invert probe pin, boolean)
$10 = 1    (Status report options, mask)
$11 = 0.010    (Junction deviation, millimeters)
$12 = 0.002    (Arc tolerance, millimeters)
$13 = 0    (Report in inches, boolean)
$20 = 0    (Soft limits enable, boolean)
$21 = 0    (Hard limits enable, boolean)
$22 = 0    (Homing cycle enable, boolean)
$23 = 0    (Homing direction invert, mask)
$24 = 25.000    (Homing locate feed rate, mm/min)
$25 = 500.000    (Homing search seek rate, mm/min)
$26 = 250    (Homing switch debounce delay, milliseconds)
$27 = 1.000    (Homing switch pull-off distance, millimeters)
$30 = 1000    (Maximum spindle speed, RPM)
$31 = 0    (Minimum spindle speed, RPM)
$32 = 0    (Laser-mode enable, boolean)
$100 = 42.828    (X-axis travel resolution, step/mm)
$101 = 42.828    (Y-axis travel resolution, step/mm)
$102 = 250.000    (Z-axis travel resolution, step/mm)
$111 = 6000.000    (Y-axis maximum rate, mm/min)
$110 = 6000.000    (X-axis maximum rate, mm/min)
$112 = 600.000    (Z-axis maximum rate, mm/min)
$120 = 36000.000    (X-axis acceleration, mm/sec^2)
$121 = 36000.000    (Y-axis acceleration, mm/sec^2)
$122 = 10.000    (Z-axis acceleration, mm/sec^2)
$130 = 200.000    (X-axis maximum travel, millimeters)
$131 = 200.000    (Y-axis maximum travel, millimeters)
$132 = 200.000    (Z-axis maximum travel, millimeters)
12 steps montage is given, check details on each image

Note that plates and gears should be parallel, take your time to check all nuts, spaces between them. Run it for sufficient long time, plastic gears needs some breaking in. Have fun, most of all!
More details on my personal webpage: https://nexp.pt/diffwrist.html
Happy printing!