
Arctic Tinyrider RC snowmobile
Obliczymy ostateczną cenę na podstawie wybranego pliku. Sprawdzisz ją i zaakceptujesz przed płatnością.
Wstępna wycena dla PETG
3,67 € – 4,49 € netto (bez VAT)
Dla pliku: MK4 PETG 2212 motor + gearing 3h37 76g.bgcode
To wstępna wycena jednego pliku. Dokładną cenę poznasz przed zamówieniem.
Plik i założenia wyceny
Plik użyty do wyceny
Średnia wycena orientacyjna: 4,08 € netto (środek widełek).
- Masa podana przez autora
- 65 g
- Czas druku podany przez autora
- 3,62 godz.
- Materiał u źródła
- PET
- Materiał wyceny
- PETG
- Drukarka wyceny
- Bambu Lab P1S - 0.4 nozzle
- Proces wyceny
- 0.20mm Standard
Orientacyjna wycena wyłącznie wybranego pliku, oparta na masie i czasie druku podanych przez autora. Warianty plików nie są sumowane. Ostateczna cena zostanie obliczona po analizie pliku.
Zapisane na tym urządzeniu.
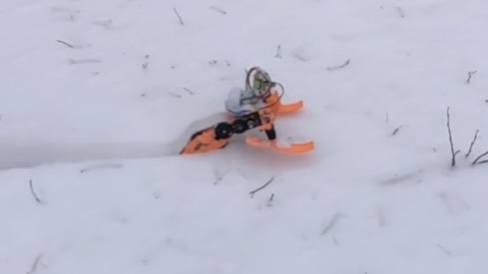
Open RC snowmobile scaled at 0,6 to original version, easy to print, easy to build, powerful and reliable
- Ocena
- 4,75 / 5
- Polubienia
- 205
- Pobrania
- 510
- Wydruki
- 4
- Wyświetlenia
- 6807
- Oceny
- 4
Aktualizacja u źródła:
Informacje o modelu
- Źródło
- Printables
- Kategoria
- RC & Robotics
- Licencja
- Creative Commons — Attribution
It's my remix scaled down of the snowmobile of 3Drcnc.
Lot of work and test on this open source project to make it easy to print, easy to build, powerful, reliable and easy to buy parts to make it (same screws and bearings for all the build)
Description under Video:
Build Guide Video:
Demonstration video:
what you need:
- 75x M3x8 BUTTON HEAD SCREW
- 14x BEARING MR128: 8x12x3,5 (buy 20 if you want to change your gearing ratio more easily)
- 2x SHOCKS WPL D12 (2screw M2,5 included with shocks for bottom shocks mounting) Alternately you can print hard shocks and buy 2x M2,5x15
- SERVO EMAX ES08MAII Alternately you can use any 9g standard size servo metal
- ESC 30A (I use cheapest brushless esc 30A)
- MOTOR BRUSHLESS 2212/2200KV (I found better speed and torque with high kv motor and appropriate gearing) but you can use any motor with max 28mm diameter front or rear mounting. I designed the pinion with 5mm hole for the 2212 outrunner motor or 3,175mm hole with m3 grub screw for inrunner motor. Motor mount holes dimensions: 16mmx19mm
- 260g Pla (200g snowmobile + 60g for solid track)
- 60g PETG or heat resistant filaments (gearing and motor mount)
- 22g TPE 85A for flex track (95A TPU work really less efficiently) Alternately you can use solid PLA track
- 1,1M of 1mm steel wire for solid track : (28x3,8cm) Alternately you can use flex track
- 3s lipo 650-1500mah (650-800mah 3s lips work great with good ratio between time/weight/power/size)
- Radio and receiver 2channel minimum
- Velcro for esc/receiver/battery installation
Support needed for ski, left side plate, right side plate
STL are in good orientation for printing
Designed for printing with 0.2mm layer height
At the end of each parts file name the quantity of parts to print is indicated (if more than one)
- Motor Mount and all gearing printed in PETG with 2 wall/100% infill/no cooling
- Track printed in TPE 85A with 1wall/0% infill/5bottom/6top layer (print slowly and don't use retraction with this filament if you don't have direct drive extrudeur)
- Drive gear part 2 printed in PLA with 2 wall/100% infill
- All other parts printed in PLA with 3 wall/20% gyroid infill/4bottom/6top layer
If your printer has a good calibration, all parts are supposed to fit perfectly together and some other parts like bearing (inside and outside), spur gear and servo ski hinge fit with tight tolerance, it’s normal. You can sand it a little if it's too hard to insert/remove parts. Tested on Prusa MK3S+ and Creality Ender 3v2
On the Upper shocks mount and arm mount, arrows point to the front to help during assembly
If you project to use gearing in PLA+, pinion melt after 2/3mn run at high speed, it's not a good idea. I didn't broke any PETG gear
You need to glue idler male and female together or you can print idler in 1 part with support
I use gearing with ratio 3 or 4,1 (G3/G4,1) with 12 teeth pinion gear for my 2212/2200kv motor but I design all gearing for ratio between 2,1 at 8,8. you can calculate the ratio with this formule→ ratio=(teeth spur gear: teeth small middle gear)x(teeth big middle gear:teeth pinion gear)
I don't use waterproof electronic and I don't have any problems with water, even when I finish with 2cm of snow on the electronic. I just use tape to protect unused receiver connector pins
motor and esc stay under 45° during the run with TPE 85A and draw only 5A at full throttle during static test
you can expect approximately 10mn of run depending the snow conditions, electronic setup and temperature
I didn't test power difference between solid track and flex track but flex track make less vibration and work more quietly: it's better for high speed
If you use TPU95A for the track you need to cut the little bridge between each round shape and use a more higher gearing ratio to avoid motor overheating
It's a very reliable and resistant design. If you are using the same setup and print settings as me you can pretty much use it non-stop and don't have to worry about parts breaking while using it. During all my test, I always pushed the snowmobile at the maximum of is potential and the only part I broke was the rod linkage because of a huge front impact. Design make it able to do a lot of rollover/flip witouth breaking
I use Esun PLA+, Esun PETG, Esun Elastic TPE 85A
G-code included for
-Prusa MK3S+ with standard 0,2mm quality, filament setting Esun PLA (standard) and prusament PETG modified (245° during print, without cooling and 0,8mm retract). Lot of modifications in setting for TPE profil (loose idler screw the maximum as possible)
-Creality Ender 3V2 with 0,2mm quality, filament setting Prusament PLA (modified lower speed) and Generic PETG (modified lower speed), no retraction to profil for TPU track
If you have any idea for improve this design you can send me a text or use step file
i Inclued Step file with my upgraded V1 Tinyrider
Arctic Tinyrider V2 coming soon