
3D Printed Servo Gripper
We calculate the final price from your selected file. You review and accept it before payment.
Saved on this device.
This mechanism converts the rotational motion of a servo motor into a clamping motion.
- Rating
- 0 / 5
- Likes
- 12
- Downloads
- 211
- Makes
- 0
- Views
- 1,329
- Reviews
- 0
Updated at source:
Model information
- Source
- Printables
- Category
- RC & Robotics
- License
- Creative Commons — Attribution — Noncommercial — Share Alike
This mechanism converts the rotational motion of a servo motor into a clamping motion using a gear-driven four-bar linkage system. Designed for hobby robotics, pick & place tasks and students.
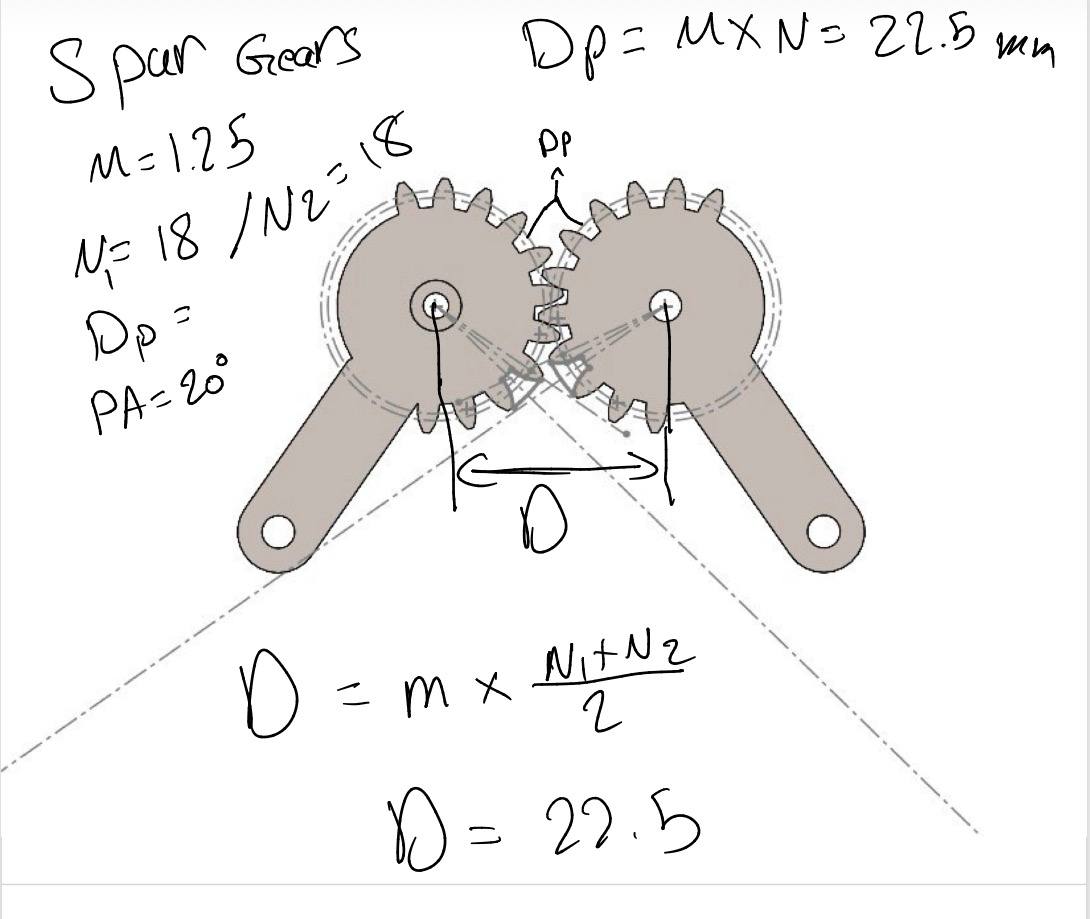
1. Gear Specifications
Standard: Spur Gear
Pressure Angle: 20°
Module: 1.25M
Teeth: 18T
Pitch Diameter: 22.5 mm
2. Theoretical Calculations
A. The horizontal distance between the two gear centers
B. Position Analysis (Four-Bar Linkage)
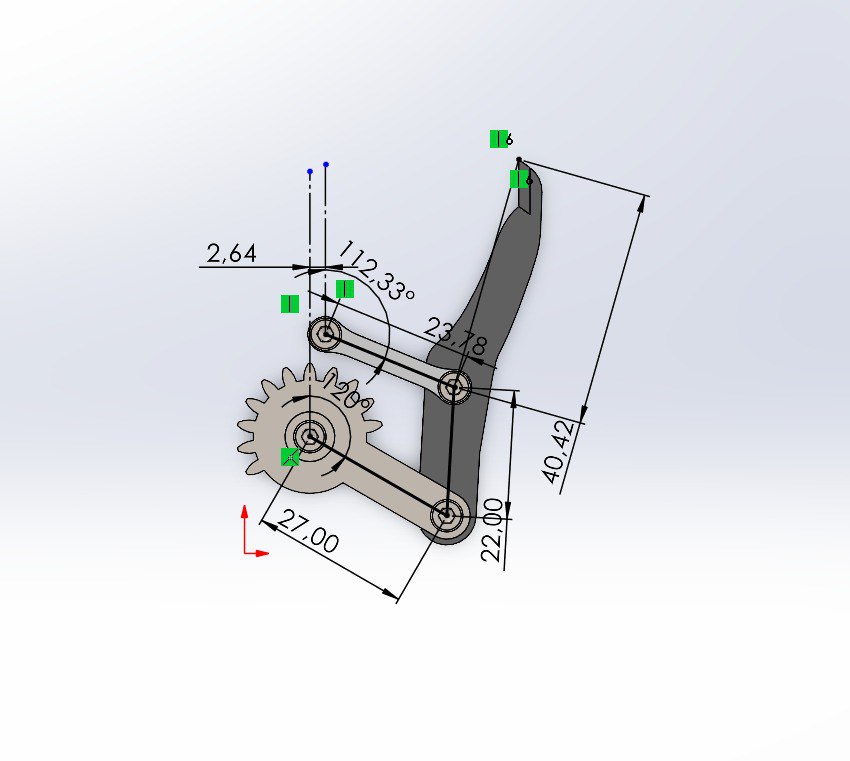
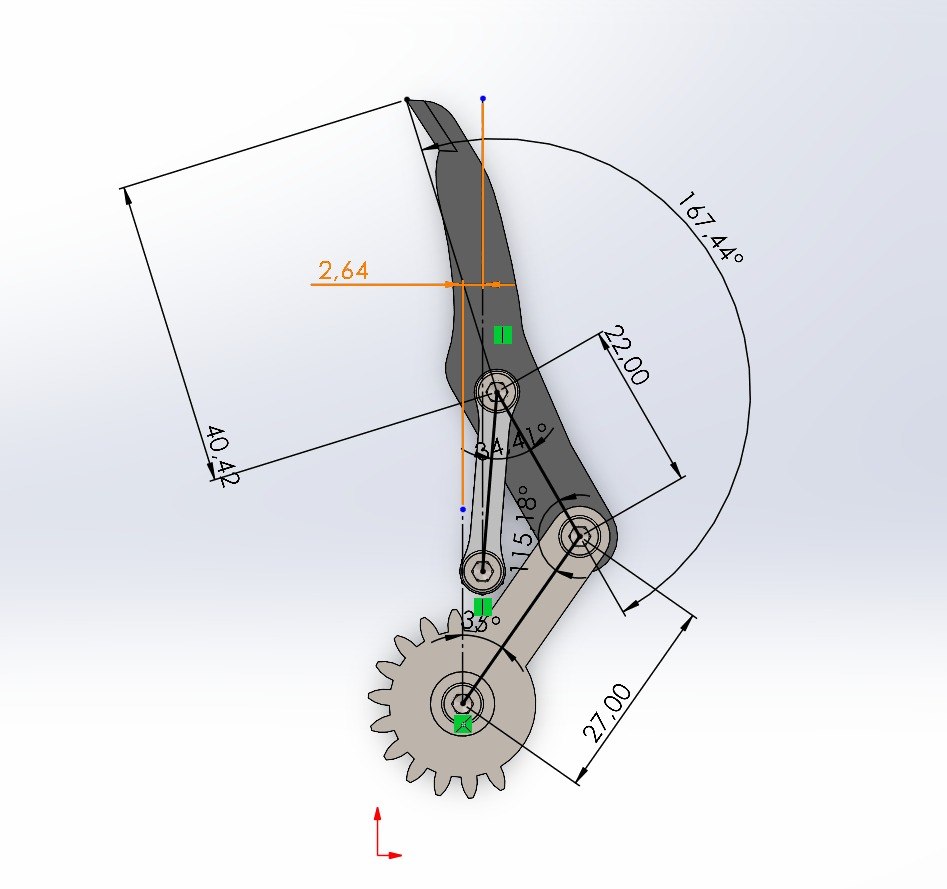
C. Recommendation: Limit the servo rotation to the specific range of 120° to 35°.
Why: To prevent mechanical interference between the components
120°: Fully Open position.
35°: Fully Closed (Grip) position.
3. Hardware
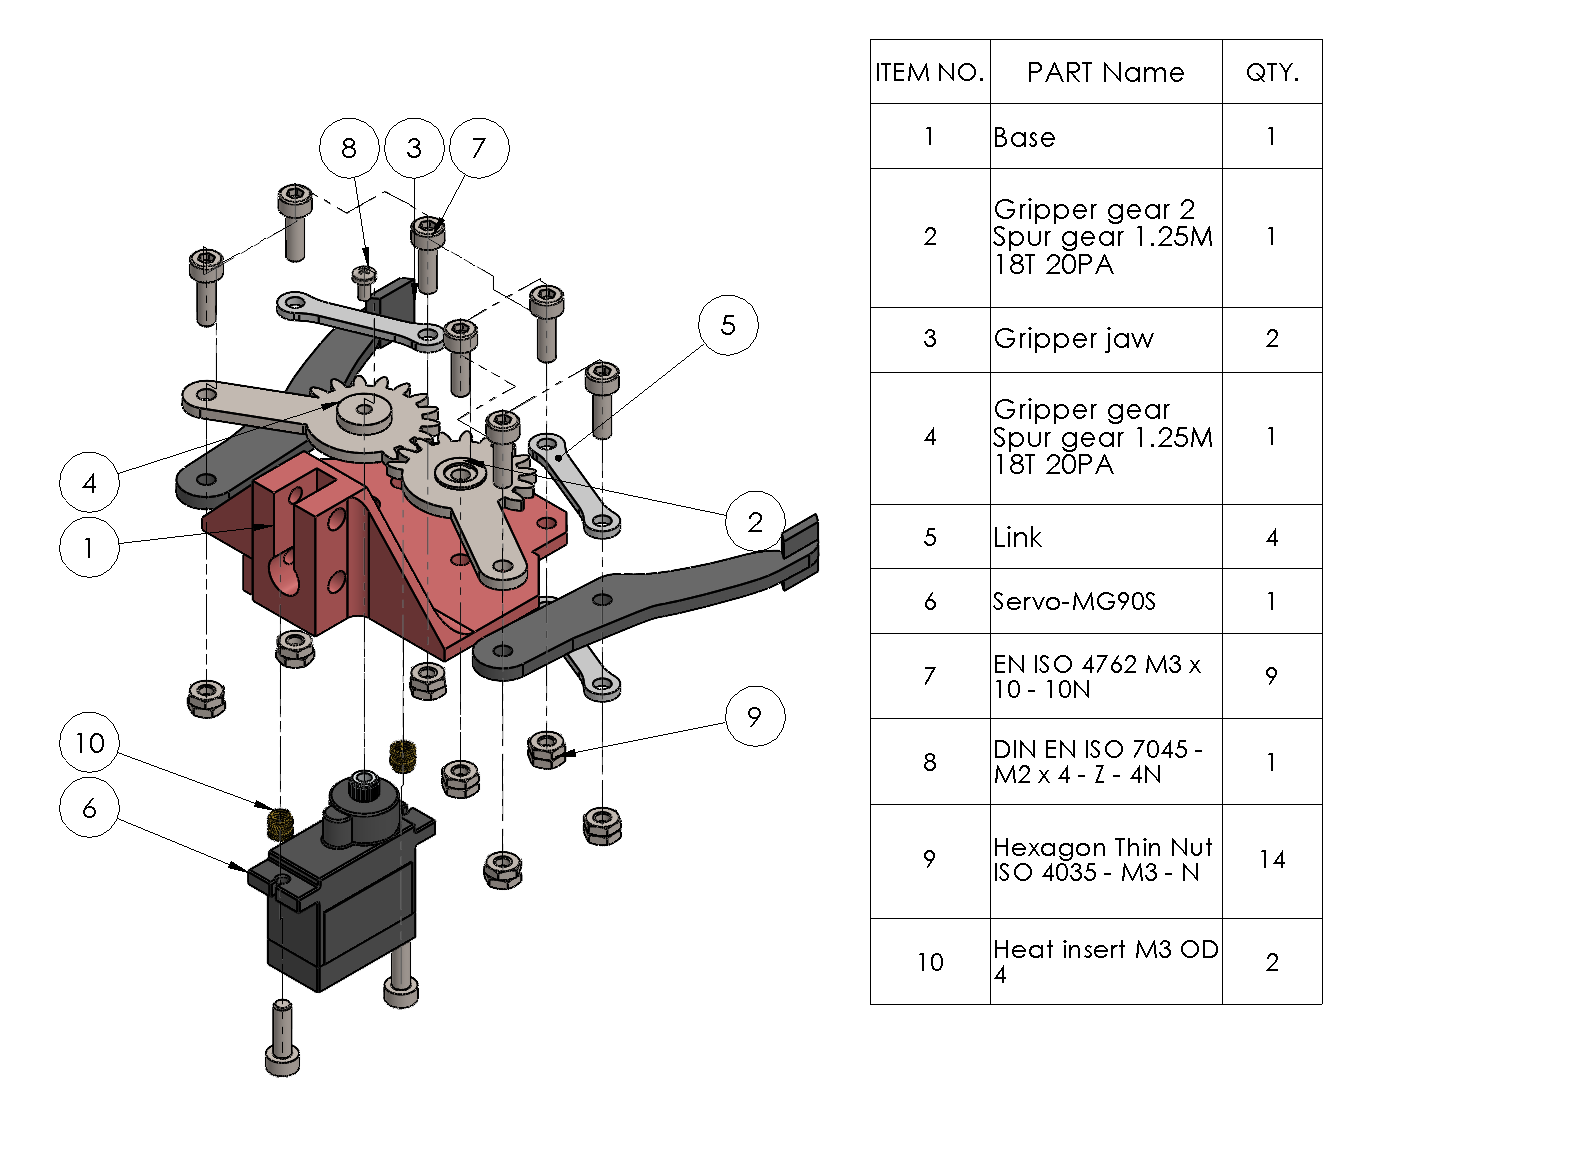
Joint Assembly Method For simplicity, the joints use a Screw and Double-Nut (Jam Nut) setup. The nuts lock against each other to maintain clearance for movement.
Alternative: Pins or Shoulder Screws.
4. Assembly & Design Videos